Nvidia and AMD Co-Lead $500M Series A in Genesis AI
US embodied-AI startup Genesis AI has raised a $500M Series A at a $3.5B post-money valuation, marking the first time Nvidia and AMD have jointly backed an embodied-intelligence company. Positioning itself as a full-stack embodied-AI player, Genesis developed the GENE-26.5 foundation model, which uses a single shared-weight model to perform long-horizon dexterous tasks in kitchens and labs, backed by a tightly coupled loop of data, models, evaluation and hardware.
Full Report
Contents6 sections
Jay reporting from Aofeisi, Quantum Bit | Official Account QbitAI
Just now, the American embodied intelligence company Genesis AI completed a new round of financing —
A $500 million Series A, bringing its post-money valuation to $3.5 billion.
The lineup of investors is quite impressive as well:
NVIDIA, AMD, former Google CEO Eric Schmidt, Zoom founder Eric Yuan, Yahoo founder Jerry Yang... a host of big names are prominently on the list.
It is worth mentioning that this is the first time AMD and NVIDIA have jointly invested in an embodied intelligence company.
At a time when financing for embodied intelligence is generally cooling, this round of funding undoubtedly stands out.
What exactly makes Genesis different?
After an in-depth study of its official website and technical documentation, we found that the answer may lie in Genesis's positioning of itself —
A full-stack embodied player.
And all of this begins half a year ago.
One Year, One Sword
Genesis AI was founded in March 2025, with headquarters spanning the United States and France, and was co-founded by Chinese scholar Zhou Xian and Théophile Gervet.
Before formally founding the company, its team had already built extremely high popularity in both academic and engineering circles through an open-source physics simulation project.
In May of this year, Genesis AI publicly unveiled its first embodied foundation model: GENE-26.5.
As soon as it was released, a series of demo videos showcasing its capabilities attracted widespread attention.
The main battleground is the kitchen.
In a four-minute, unaccelerated video, the robot smoothly completed more than 20 subtasks:
Cracking eggs with one hand, slicing tomatoes with a knife, using a whisk, a salt grinder, and a spatula.
The next scene is the laboratory.
Also requiring millimeter-level precision, and also a long-horizon task captured in a single continuous shot, GENE-26.5 can autonomously perform pipetting, seal test tubes, and ultimately place the test tubes into a centrifuge.
In addition, it can make milkshakes, solve a Rubik's cube, and play the piano, comprehensively demonstrating the general manipulation capabilities of its dexterous hand.
The most critical point is that these capabilities are not stacked together from multiple specialized small models; the vast majority of operations rely on the same shared-weight GENE model.
However, in today's robotics field, demo videos are no longer rare, and the methodology behind them is perhaps more worth exploring.
Genesis has something rather special: the company states that the model is not all they want to showcase.
In their view, a robot is a highly coupled engineering system. Data, evaluation, the body itself... a shortcoming in any one link will, like dominoes, ultimately limit the upper bound of overall performance.
So what to do?
Genesis's answer is:
I want it all.
Deconstructing the Full-Stack "Trinity"
In Genesis's system, data, models, evaluation, and the body are designed as a tightly coupled closed-loop system.
1. Data Engine: Solving the "Chicken-and-Egg" Problem
One of the biggest bottlenecks in robot learning is the scarcity of high-quality data, especially hand manipulation data.
Human hands can produce the richest and most natural interaction data, but the morphological gap between human hands and robotic hands is enormous, making it difficult to transfer data directly.
But what if this embodiment gap did not exist?
Genesis's solution is almost brute-force: they directly filled in this gap at the physical level —
1:1 full-chain mapping.
- The human hand: the source of all interaction.
- Data glove: using electromagnetic field (EMF) finger tracking technology and high-density tactile sensing to capture signals from the human hand at work with high fidelity.
- The Genesis dexterous hand: adapted 1 to the human hand, with 20 degrees of freedom, and its surface covered with a flexible material that mimics human skin.
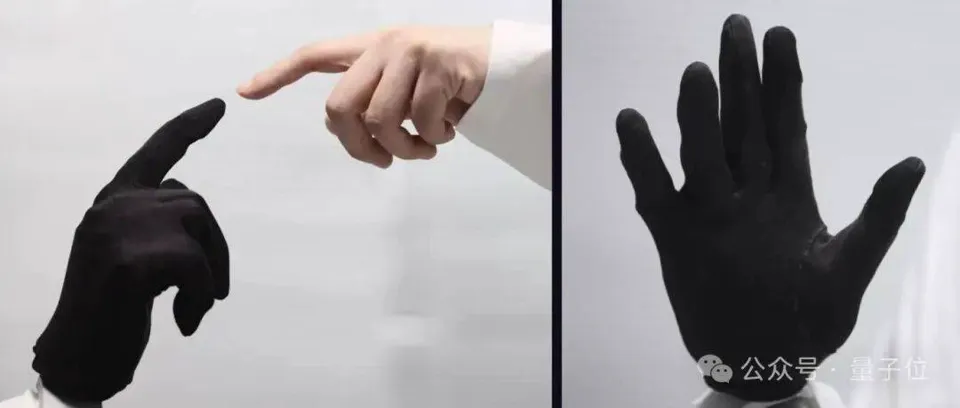
The effect is that when workers wear data gloves to perform their daily work, their hand movements and tactile signals can be collected with high fidelity and transferred to robot learning almost losslessly.
Work is data collection.
Through this approach, by May of this year, Gene had already used more than 200,000 hours of multimodal data. We have learned that this data volume has now reached the scale of millions of hours.
This is precisely the charm of the full-stack approach.
Many problems that seem thorny at the model layer may find more fundamental solutions when approached from the system layer.
2. Genesis World: Turning Iteration into a Compute Problem
Data is the raw material, and the speed of model progress depends on the efficiency of "processing" that raw material.
If every model improvement had to be validated in the physical world, the R&D cycle would be greatly slowed down. Genesis's solution is: go all in on simulation.
We view simulation as the evaluation and iteration engine for robot foundation models, not merely as a data generator. Real-world experiments limit how quickly we can score candidate solutions; simulation removes this limitation, turning the development cycle from a wall-clock problem into a compute problem.
This is Genesis World, a "Hyperbolic Time Chamber" where robots can train and test themselves.
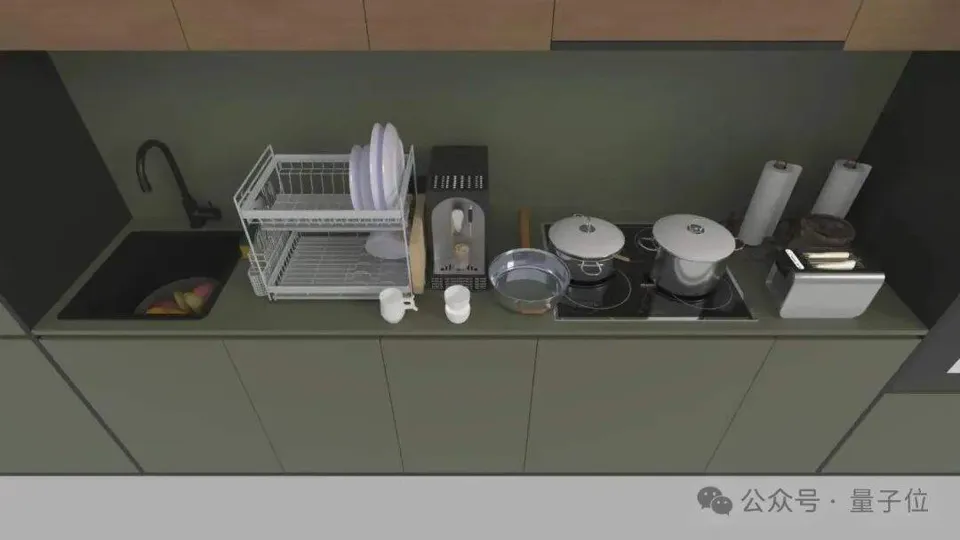
The results are remarkable.
A single model evaluation may involve hundreds of tasks, each repeated hundreds of times. In the real world, this would require an operator and a robot working continuously for more than 200 hours.
In Genesis World, the same tens of thousands of tests can be completed in less than half an hour, without any human or hardware intervention.
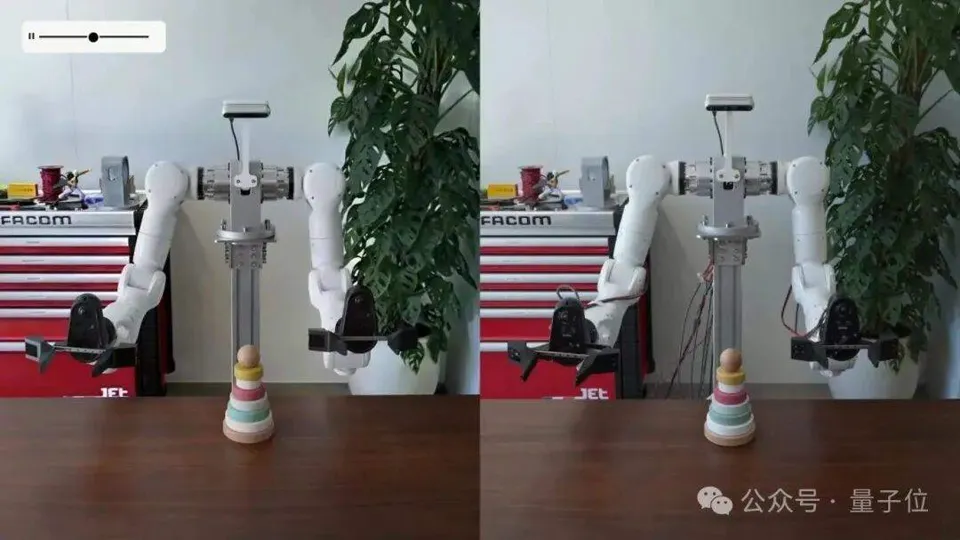
Of course, the premise of all this is "trustworthiness."
To narrow the Sim-to-Real gap, Genesis has invested enormous effort in developing its own rendering engine Nyx, cross-platform compiler Quadrants, and unified physics engine.
Ultimately, in controlled experiments conducted officially, simulation evaluation and real robot test results showed a strong correlation, with a Pearson correlation coefficient of 0.8996.
Beyond the simulation engine, Genesis has already built an internal pipeline for automatically generating tasks, environments, objects, and reward functions, allowing robots to self-evolve in large-scale automatically generated simulation environments.
3. Eno: Born for "Getting Work Done"
But at this point, only the preparatory work has been completed.
Data, simulation, models — all of this ultimately needs a product form to carry it and to build a bridge to the physical world.
For Genesis, that product is Eno.
Eno's minimalist and timeless design was called "the iPhone moment for robots" by Forbes magazine.
It's worth mentioning that Eno has just won the Gold Award at the German Design Awards. It is not the handsome bipedal humanoid robot we imagine. Instead, it has a wheeled base, and its torso is folded from several panels.
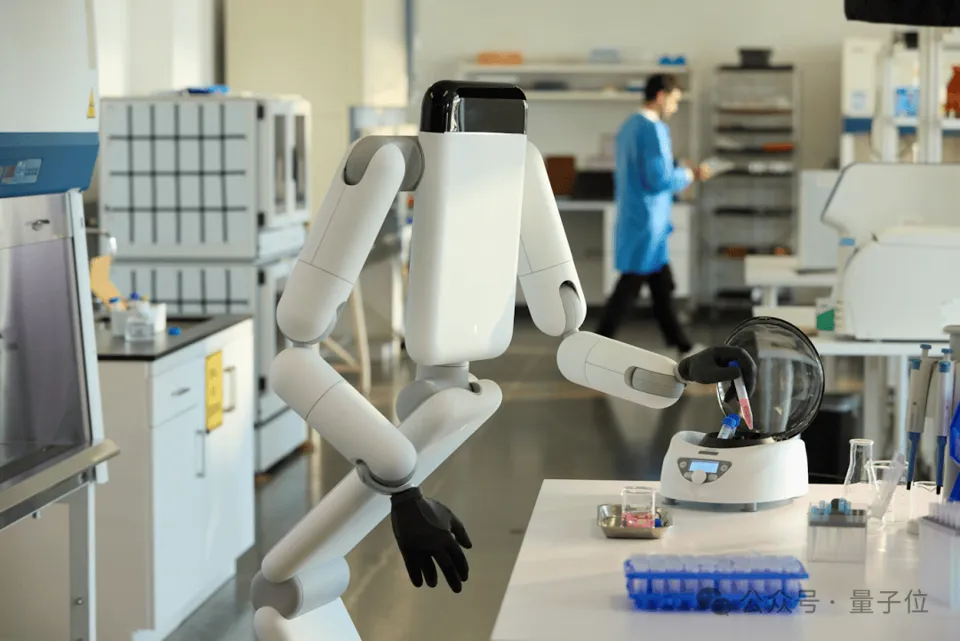
Airplanes don't need bird wings. By the same token, many human features may actually be a burden for machines.
From the very beginning, Eno's design goal was never to imitate "human appearance." But this instead gives it the most "human-like capabilities," while packing these capabilities into an elegant and minimalist body.
Wheels ensure movement efficiency and battery life; a body that can rise and lower allows it to adapt to workbenches of different heights.
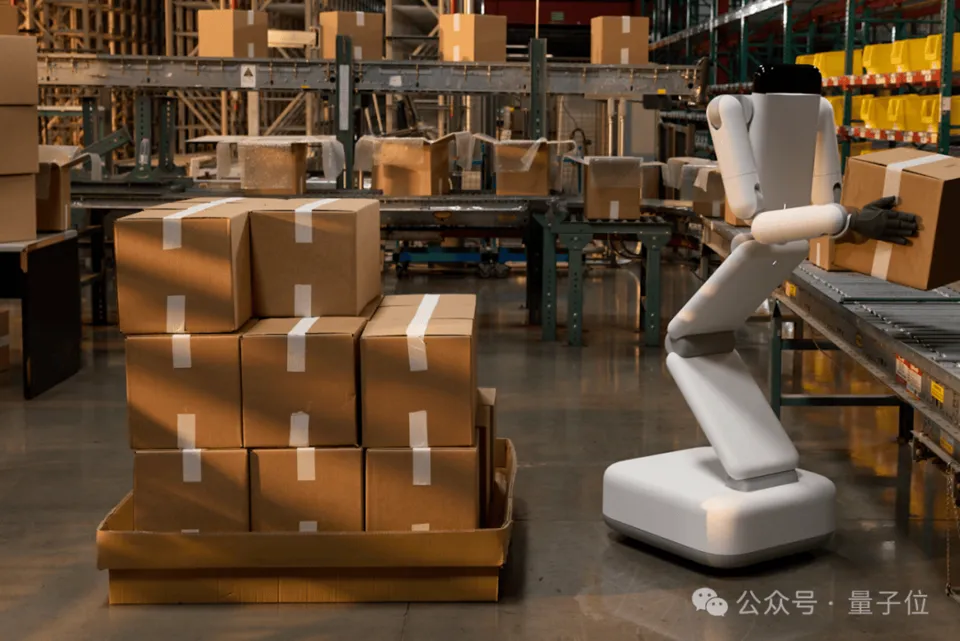
Every design choice serves function, efficiency, and cost. Behind this is the same embodiment of first principles—full-stack embodied native.
As Genesis CEO Zhou Xian said in the financing statement:
Our mission is to eliminate the limits placed on human ambition in the physical world. To achieve this, we are building the world's best general-purpose robot, one that can work reliably day after day in the real world. This requires intelligence, hardware, and everything needed to train and test robots to operate together as a single system. By building all of this ourselves, we can obsess over every detail and improve the entire robot faster.
Deployment Is King
With $500 million in hand, what's the next step?
Mass production.
Genesis said this round of financing will mainly be used to drive large-scale mass production and deployment of Eno in the real world.
Specifically, they plan to begin production and customer deployment by the end of 2026, first entering industrial environments such as manufacturing, logistics, and laboratories, then expanding to service industries such as hotels and hospitals, and finally entering consumer-grade home and outdoor applications.
From structured to unstructured, one step at a time.
But to be honest, even just taking this first step is extremely difficult.
Demo videos can offer unlimited room for imagination, but once deployment is involved, "reliability" is the only yardstick.
The embodied intelligence chain is extremely long, and an error in any link can lead to a full-scale collapse in real-world scenarios.
At the same time, the long-tail problems of the real world are complex and varied. Only after struggling through real scenarios can delivery standards be gradually met.
Technology and product must advance together. Training models while sitting in a lab is not enough. Getting Hands Dirty is something that must be done. Only on the front line can the model-deployment-data loop be achieved.
From this perspective, mass production and deployment itself may also be an indispensable part of the embodied intelligence R&D process.
Over the past few years, the debate over the path to general-purpose robots has often revolved around "humanoid" versus "non-humanoid."
Now, Genesis AI offers a new frame of reference: the real dividing line may not lie in appearance, but in the R&D paradigm.
AGI in the physical world is a far more grueling and protracted battle than large language models.
When a system becomes complex to a certain degree, local optimization will eventually hit a bottleneck. Only by keeping all variables in your own hands and thinking, designing, and iterating as a whole can breakthroughs be possible.
Computer pioneer Alan Kay left a maxim decades ago:
People who are really serious about software should make their own hardware.
This is true of Tesla building cars, and also true of Apple making consumer electronics. Now, more and more embodied intelligence companies like Genesis are proving:
Building robots must be the same way.
Today, with OpenAI and Anthropic also beginning to bet on robot brains, this may be the only path to physical AGI.