Ant Group's Lingbo Open-Sources LingBot-Touch Tactile Foundation Model
Ant Group's Lingbo Technology has open-sourced LingBot-Touch, a tactile foundation model pretrained on nearly 5,000 hours of real tactile data that unifies magnetic, visuotactile and piezoresistive sensor signals into a single representation reusable across dexterous hands and action models. Across 26 real-robot tasks, plugging it into four action models lifted success rates by roughly 14 to 26 percentage points, with bottle-cap twisting rising from 56.25% to 90%. The model, code and technical report are released on Hugging Face, GitHub and ModelScope.
Related Entities
Full Report
Contents3 sections
On November 10, Ant Lingbo Technology open-sourced LingBot-Touch, a tactile foundation model
On November 10, Ant Lingbo Technology open-sourced LingBot-Touch, a tactile foundation model that fills in the critical tactile perception capability for robot brains. The model is pretrained on nearly 5,000 hours of real tactile data and covers three mainstream sensing principles: magnetic tactile, visuotactile, and piezoresistive. It can convert different signals into a unified tactile representation for use by different dexterous hands and action models, enabling robots to "see clearly and think clearly" while further filling in the tactile perception required for fine manipulation.
At a time when general large models are accelerating, choosing to release a tactile foundation model oriented toward the closed loop of physical manipulation conveys Ant Lingbo's continued investment in and commitment to the embodied-native route.
Previously, Ant Lingbo's general brain had already covered high-precision spatial perception, high-dynamic environment interaction, and generalizable dexterous manipulation, enabling robots to see more clearly, think more clearly, and act more deftly. LingBot-Touch has now been integrated into LingBot-VLA, extending perception to the "fingertips" so robots can "feel more sensitively," further enhancing the capabilities of the embodied-native general brain.
26 real-robot tests: task success rate improves by 14 to 26 percentage points
As general large models continue to advance, robots' ability to understand complex tasks and reason about manipulation steps is strengthening. But in the real physical world, every step a robot executes requires perceiving changes in the object and environment, then correcting the next action. In many fine manipulation tasks, the robot can see where the object is and can move its hand to the correct position, yet it may not successfully complete the task, because after the fingers touch the object, it is difficult to judge by vision alone whether the force is appropriate or whether the object is slipping; tactile sensing is needed to provide supplementation.
Take tightening a bottle cap with a dexterous hand as an example. Depth information can help the fingers align with the cap. After rotation begins, the cap may already be loose, or the fingertip pad may be slipping along the cap wall. These two situations look similar in the image but require different action adjustments. At this point, the contact position at the fingertip, the magnitude of force, and their changes become important bases for the action model's judgment, yet this information is often occluded by the fingers and the object and is difficult for vision to obtain.
To verify the help of tactile representations for real manipulation, Ant Lingbo conducted 26 real-robot tests on two dexterous hands, Sharpa Wave and XHand1, covering fine manipulation tasks such as turning book pages, tightening bottle caps, and recognizing mahjong tiles. After integrating LingBot-Touch, the average task success rates of four action models—LingBot-VLA, π0.5, Diffusion Policy, and T-Rex—improved by about 14 to 26 percentage points compared with the no-tactile setting.
Taking T-Rex controlling Sharpa Wave to tighten a bottle cap as an example, the task success rate was 56.25% without tactile sensing, 62.5% with raw sensor signals directly input, and 90% after integrating the tactile representation from LingBot-Touch.
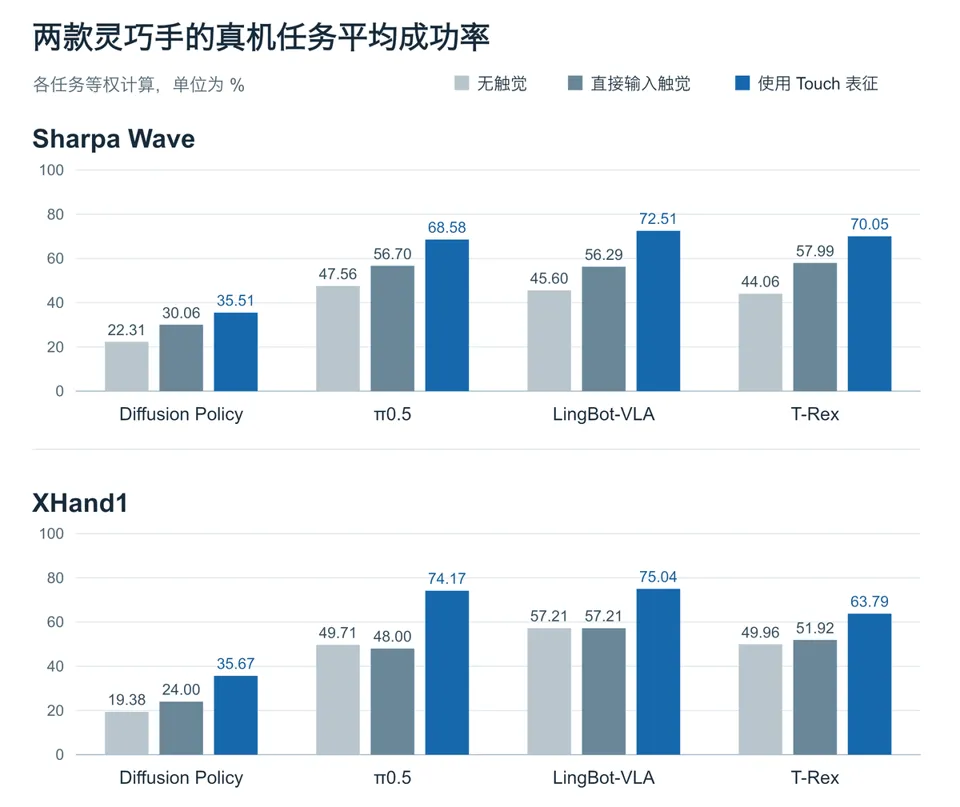
(Caption: After integrating LingBot-Touch, the real-robot task success rates of the four action models on the two dexterous hands all reached their respective highest levels.)
Unified tactile representation enables robots' "sense of touch" to be reused across hardware
Installing tactile sensors on a robot does not mean it can use touch well. At present, commercial tactile sensors as a whole are still at an early stage of development. Mainstream routes such as visuotactile, magnetic tactile, and piezoresistive each have advantages and limitations, and multiple technical routes may coexist for a long time for different costs and use scenarios.
More troublesome is that the data collected by these sensors is difficult to use directly across systems. The same contact, under different sensing principles and contact layouts, will form different raw signals. If a model learns to interpret only one of them, then after changing sensors or dexterous hands, existing data and tactile experience may be difficult to reuse, requiring new collection, training, and adaptation. At a time when hardware is iterating rapidly, this binding causes repeated development and increases adaptation costs among hardware vendors, complete-machine teams, and model developers.
Therefore, the key to scaling tactile sensing toward large-scale deployment is to free tactile understanding from dependence on the physical signals of specific sensors, so that data from different sources can be used together for training and accumulated tactile capabilities can be reused across sensors, dexterous hands, models, and tasks.
To this end, LingBot-Touch sets up separate encoding entrances according to sensing principles, first processing different raw signals, then mapping contact points from different layouts into a unified fingertip coordinate space, where a shared model learns contact position, force, and their changes over time, and outputs unified tactile Tokens. As a result, data collected by people wearing tactile gloves and by teleoperated dexterous hands can be used together for training, and different action models can also use the trained model to extract contact features. This architecture also leaves room for expansion to integrate new types of tactile sensors in the future.
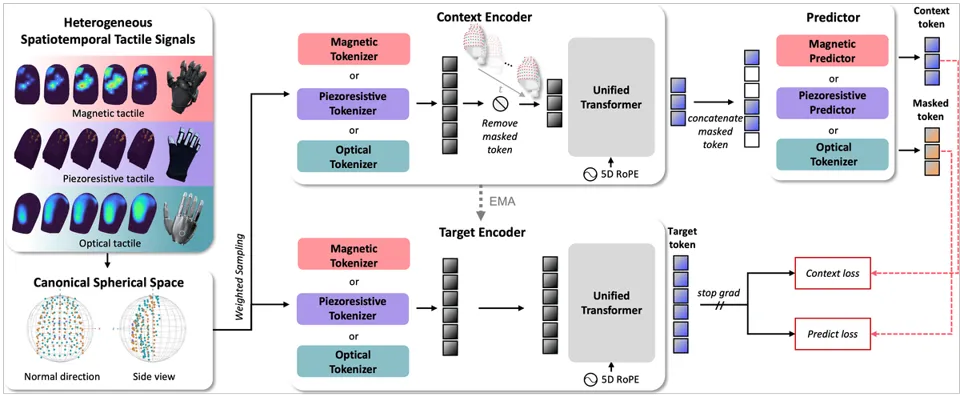
(Caption: LingBot-Touch encodes magnetic tactile, visuotactile, and piezoresistive tactile signals into unified tactile Tokens for use by different action models.)
On XHand1, the team further verified cross-hardware reuse of tactile capabilities. The magnetic tactile sensor model used by XHand1 was not in the pretraining data; all the magnetic tactile experience learned by the model came from data collected by people wearing gloves. After switching to this dexterous hand, the team kept LingBot-Touch parameters unchanged and trained the action model only with XHand manipulation demonstrations.
At the same time, LingBot-Touch was integrated with four different action models in this real-robot test and is not bound to Ant Lingbo's self-developed models. What it provides is a general perception capability located between tactile sensors and action models, rather than a dedicated module for a particular hardware or policy. For the industry, sensor and dexterous-hand vendors can choose hardware according to cost and task requirements, and complete-machine teams can also retain their own action policies, thereby reducing the repeated investment of redeveloping tactile capabilities every time a hardware and algorithm combination is changed.
To balance perception capability and on-device compute, Ant Lingbo provides models in two capacities. All 26 real-robot tests this time were completed using the lightweight version LingBot-Touch-Tiny with about 5.3 million parameters. After integration into LingBot-VLA, π0.5, and T-Rex, the model parameter count increased by only about 0.13% to 0.16%.
The larger-capacity version, LingBot-Touch-Small, showed potential for further improvement in perception tests—when pretraining data increased to nearly 5,000 hours, the model could still benefit from the newly added data, indicating that tactile pretraining still has room for continuous scaling and improvement.
Adhering to embodied-native development and advancing in coordination with general large models
Regarding the recent evolution of embodied large model technology roadmaps, Ant Lingbo CEO Zhu Xing stated: "The progress of digital-world large language models represented by GPT-6 Astra and Claude Fable 5.2 has indeed made robots' complex task reasoning and physical manipulation capabilities stronger—this is something we closely follow and are actively absorbing. But frontline industry practice tells us that to truly close the manipulation loop, the hard nut of physical manipulation generalization remains unavoidable, and to a large extent it still depends on breakthroughs in embodied foundation models themselves."
In his view, general large models and embodied foundation models are closer to a 1+1>2 synergistic relationship: the former enhances understanding and reasoning about tasks and environments, while the latter improves physical perception and closed-loop manipulation capabilities. Each achieves its own breakthroughs and mutually reinforces the other, jointly accelerating the maturation of the embodied intelligence industry.
"The quality of modality input largely determines the quality of action output—in other words, no good input means no good output," Zhu Xing said. Ant Lingbo will adhere to the embodied-native approach, continuously explore new upper limits of physical manipulation generalization, build a cross-configuration general-purpose brain for the robotics industry, promote the alignment of more physical modalities—including vision, depth, touch, and even temperature—within a unified model, and continue to open-source and open up to the community while advancing commercialization.
Currently, the technical report, model, and code for LingBot-Touch have been open-sourced, and developers can access and download them on Hugging Face, GitHub, and the ModelScope community.
This article is provided by Ant Lingbo. QbitAI is authorized to repost it, and the views belong to the original author.